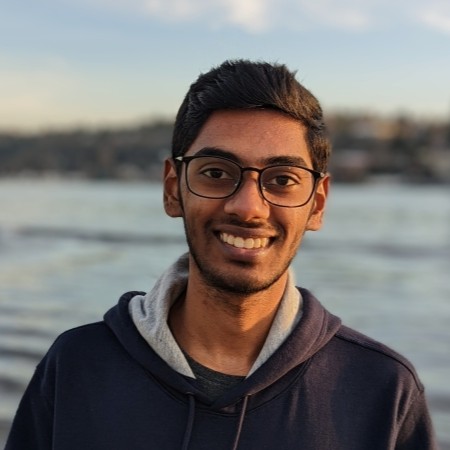
Srivatsan Balaji
Research & Development Intern/Contributor
Nimble Surgical
Interests: Soft and Materials Robotics
I am contributing to the development of metamaterial-based tip-transforming catheters at Nimble Surgical. Previously, I was a Faculty Research Assistant in the Intelligent Machines and Materials Lab, part of the Collaborative Robotics and Intelligent Systems (CoRIS) Institute at Oregon State University. I developed hardware for integrating flexible sensors for augmenting human-supervised underwater grasping. Prior to this, I built and characterized electrically-driven soft grippers and a robot arm, and improved the performance of Pneu-Net actuators.
My work sits at the intersection of mechanical engineering, robotics, materials, and computation to some extent. I design the system, fabricate it, characterize it, then feed what I learned back into the design.
Outside of work, I am a virtual pilot and hobbyist photographer.
Read more about my work on the research page.